Abstract background design

Hello, I'm Ananya!

I'm an engineering student at IIT Guwahati, majoring in Electronics and Electrical Engineering.

I'm passionate about digital and analog IC design, exploring FPGA-based systems, and building hands-on expertise in ASIC design flows.

When I'm not in front of a screen, you'll probably find me on the basketball court, flipping through a book, or throwing a punch or two in taekwondo! Always up for a challenge
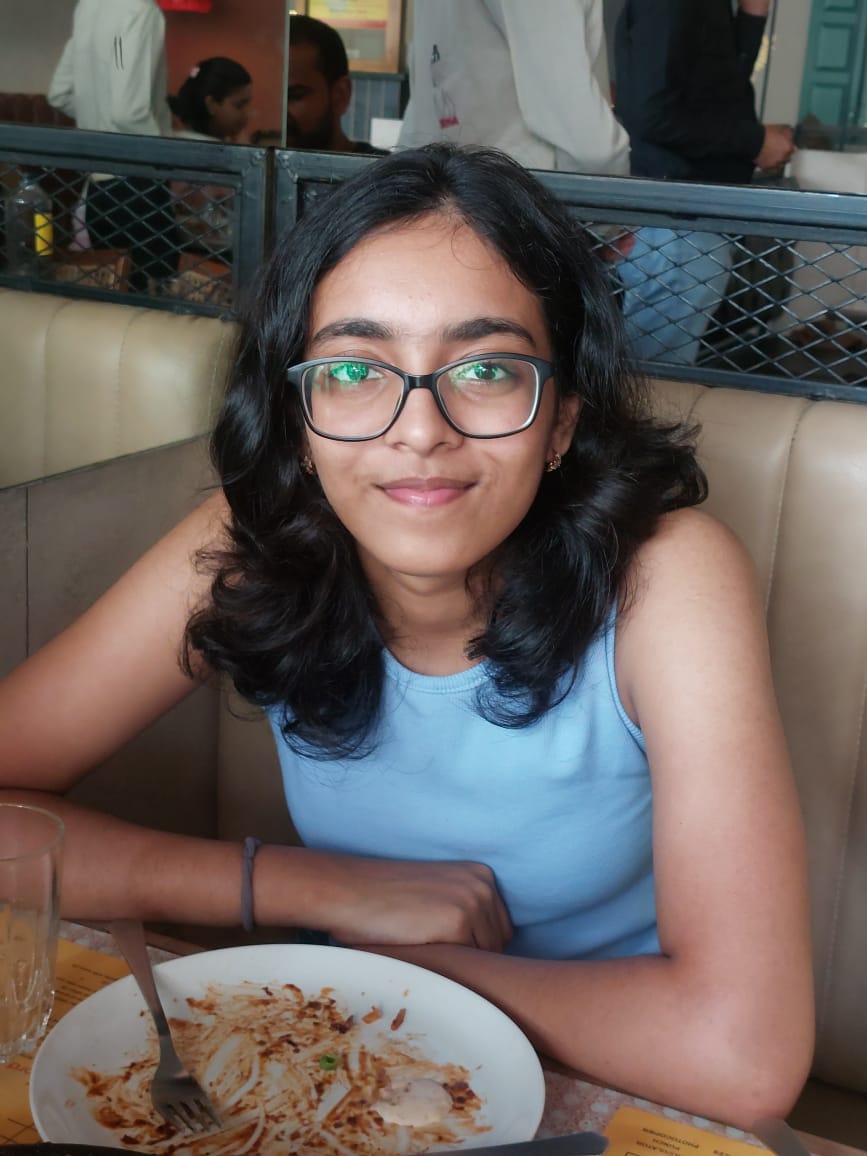
Your Profile Picture

Electronics and Electrical Engineering

IIT Guwahati

Summer Intern @ IIT Bombay | Project Manager @ RoboticsClub IITG | e-Yantra 2026 Finalist

About Me...

I'm Ananya Dongsarwar, born and raised in Pune, Maharashtra. I'm currently pursuing my B.Tech at IIT Guwahati, with a passion for FPGA design, ASIC/VLSI design, and analog circuit design. When I'm not building circuits or exploring digital/analog design flows, you'll probably find me shooting hoops, diving into a good book, or practicing Taekwondo — I'm a proud black belt! I'm always excited to connect, collaborate, and contribute to meaningful projects. Whether it's a new chip design idea or a challenging problem to solve, I'm all ears!

My Projects

Design and Development of Decentralized Multi-Robots

Summer Intern · eYSIP 2026, IIT Bombay | May 2026 – Present

Designing and developing dedcentralized holonomic drive robots using Raspberry Pi 4 and STM32 microcontrollers for real-time motor and sensor control on a distributed hardware-software architecture. Establishing full-duplex UART between the Pi and STM32, and half-duplex I2C across daisy-chained ST3215 servo motors for precise closed-loop motion control. Developing a decentralized multi-robot system for shared environment mapping and autonomous exploration.

FPGA-Based Maze Solver Bot

e-Yantra 2025 · IIT Bombay | Aug 2025 – Mar 2026

Finalist — ranked 5th of 2,500+ participants. Built an autonomous FPGA-powered robot on the Intel DE0-Nano with a custom CPU architecture for parallel sensor, motor, and communication processing. Designed a dynamic maze-solving algorithm for changing warehouse layouts with a custom sensor PCB, scoring 100% on robot design efficiency, and implemented UART-based wireless data transmission.

Autonomous Warehouse Navigation Robot

NXP AIM 2025 · NXP Semiconductors | Jun 2025 – Aug 2025

Advanced to the Regional Finale, competing against 5,000+ participants and 2,000+ teams nationally. Programmed an autonomous mobile robot using LiDAR-based SLAM mapping and an angle-reference method for shelf localization, achieving 95% object recognition accuracy and a 60% reduction in search time.

Single-Cycle RISC-V CPU

Digital Design · Personal Project | Sept 2025 – Oct 2025

Implemented a single-cycle RV32I RISC-V processor in Verilog supporting the full base integer ISA, sub-word memory access, and all branch/jump instructions. Validated 37 RV32I instructions via ModelSim testbench, with a Harvard-architecture memory and fully decoded controller-datapath design.

2-Stage OTA

Analog IC Design · EE206 Course Project (Prof. Mahima Arrawatia) | May 2025

Designed and simulated a two-stage OTA in TSMC 180nm CMOS using LTspice, achieving a 73 dB DC open-loop gain. Hand-calculated transistor sizing from small-signal parameters, configured as a non-inverting amplifier (gain = 2), and validated via DC, transient, and AC analysis.

Get in Touch!

Have a project in mind or just want to say hello? Fill out the form below!